Receding-Horizon Nullspace Optimization for Omnidirectional UAVs
Actuation-aware control allocation that uses nullspace redundancy to smooth motor commands while preserving the desired wrench.
Robotics · Control · Learning
PhD researcher at Tampere University
I work on robotic systems that need to operate reliably in the real world, bringing together control, optimization, and learning.
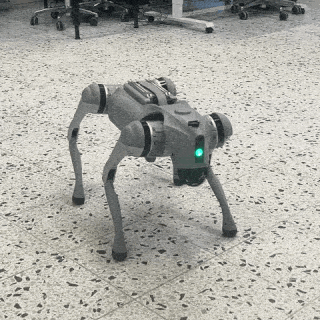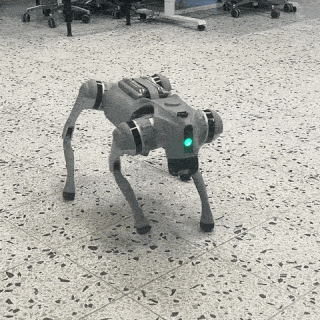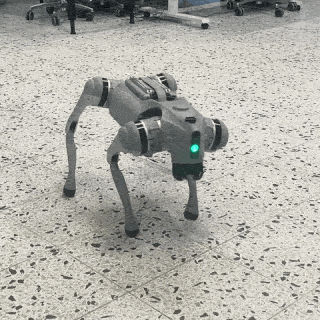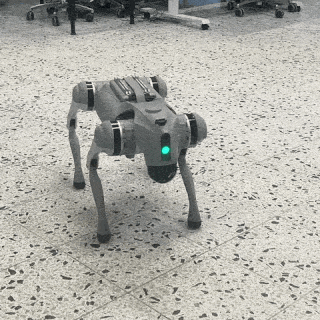
Selected work
A selection of projects exploring how robotic systems can be controlled and coordinated under real-world constraints.
Actuation-aware control allocation that uses nullspace redundancy to smooth motor commands while preserving the desired wrench.
Uncertainty-aware trajectory optimization, model predictive control, and whole-body control for robust object transport.
About me
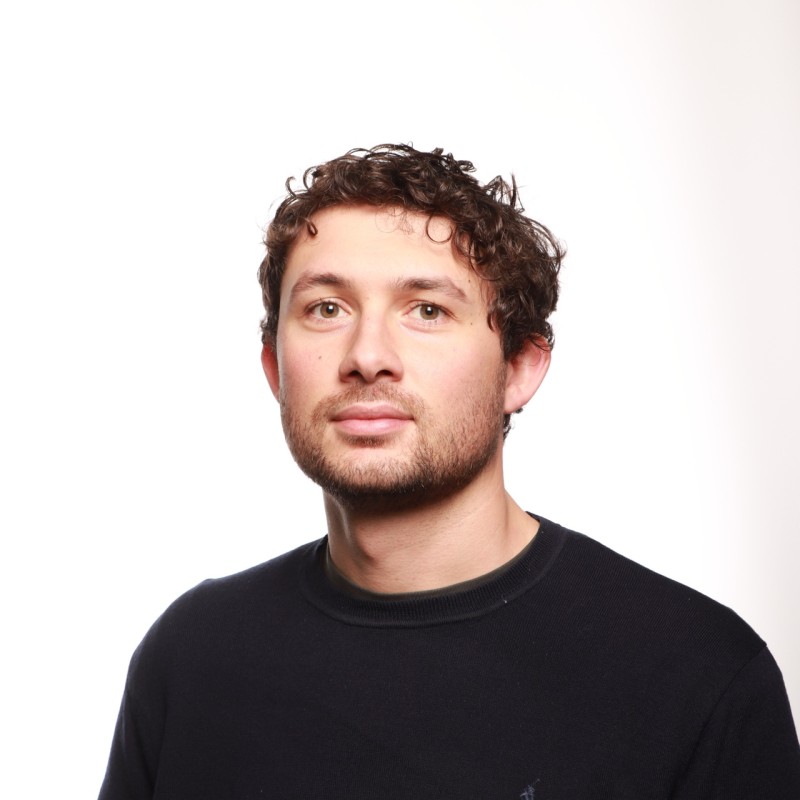
I’m Riccardo, a PhD researcher at Tampere University. My interests lie in making robotic systems behave reliably in complex physical environments.
My work spans aerial robots and quadruped systems, with a focus on model-based control, optimization, and learning. I enjoy research that connects principled methods with practical experiments.
For research discussions, collaborations, or opportunities.